About on Visualise Path Planning Algorithm For Robots In Static Environment
Looking for the latest information on Visualise Path Planning Algorithm For Robots In Static Environment? We've researched comprehensive data, records, and insights about Visualise Path Planning Algorithm For Robots In Static Environment.
Key Details
Explore the key sources for Visualise Path Planning Algorithm For Robots In Static Environment.
Developments
Stay updated on Visualise Path Planning Algorithm For Robots In Static Environment's latest milestones.
Path Planning for Robotics - Computerphile
PATH PLANNING ROBOT
A* (A Star) Search | TurtleBot3 Robot | Motion Planning for Robots
Static Path Planning for Mobile Robot using Potential Field Method
An anytime implementation of the RRT algorithm
Rover Path Planning with Dijkstra's algorithm
An Efficient Sampling-based Method for Online Informative Path Planning in Unknown Environments
Modern Robotics, Chapter 10.5: Sampling Methods for Motion Planning (Part 1 of 2)
Graph-based Path Planning for Autonomous Robotic Exploration in Subterranean Environments
Lecture 9: Multi-Robot Path Planning
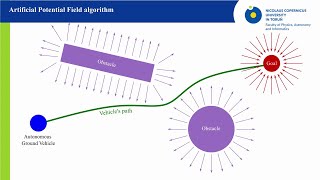
Predictive Artificial Potential Field algorithm - energy-efficient local path planning algorithm
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: October 5, 2026
Conclusion
For 2026, Visualise Path Planning Algorithm For Robots In Static Environment remains one of the most talked-about information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
This is our fourth and last lecture on the topic of In this video, I introduce two important concepts in Need to get to your goal quickly? Ensure you plan the right An autonomous bot which reaches the destination via shortest A* (A Star) is one of the most optimal Potential Field Method is used to simulate A simulator test of ArduPilot rover navigating around a complex polygon fence using Dijkstra's The presented framework is available on Github! - github.com/ethz-asl/mav_active_3d_planning Additional information can ... This is a video supplement to the book "Modern This work presents a new strategy for autonomous graph-based exploration A brief presentation of the Predictive Artificial Potential Field
Visualise Path Planning Algorithm For Robots In Static Environment.pdf
What is the most accurate information about Visualise Path Planning Algorithm For Robots In Static Environment?
Our platform aggregates the most comprehensive and up-to-date insights, ensuring you get relevant details about Visualise Path Planning Algorithm For Robots In Static Environment.
Why is Visualise Path Planning Algorithm For Robots In Static Environment trending right now?
Interest in Visualise Path Planning Algorithm For Robots In Static Environment has surged recently as more people seek reliable resources, related media, and detailed analysis.
Where can I find related media and updates for Visualise Path Planning Algorithm For Robots In Static Environment?
You can explore extensive galleries, video summaries, and related content directly on this page.
How often is the content about Visualise Path Planning Algorithm For Robots In Static Environment updated?
We regularly update our database with the latest information, media, and analysis related to Visualise Path Planning Algorithm For Robots In Static Environment.