Looking for the latest information on Rapidly Exploring Random Trees? We've compiled comprehensive data, records, and insights about Rapidly Exploring Random Trees.
Core Information
Explore the primary sources for Rapidly Exploring Random Trees.
Developments
Stay updated on Rapidly Exploring Random Trees's latest milestones.
Rapidly Exploring Random Trees
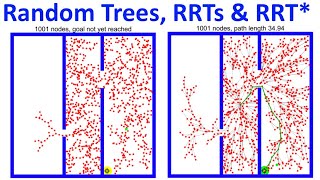
Princeton Intro to Robotics (Fall 2026) | Lecture 3: Rapidly Exploring Randomized Trees (RRTs)
Dynamic Domain Rapidly-exploring Random Tree on mobile robot simulation
Rapidly Exploring Random Tree
12 3 Rapidly exploring random trees
Extended Rapidly Exploring Random Tree Demonstartion
Rapidly-Exploring Random Tree
Kinodynamic Rapidly Exploring Random Trees (RRT) for Autonomous ISS Inspection
RRT* Finding a Path
ROS2 Exploration using Rapidly-exploring Random Trees
Rapidly Exploring Random Tree Algorithm (RRT)
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: September 27, 2026
Final Thoughts
For 2026, Rapidly Exploring Random Trees remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
A tree generated by random motion from a randomly selected tree node does not explore very far. A VDEngineering ~~My Udemy Courses on Motion Planning / Navigation / Trajectory Planning: ... The algorithm can be found in section 5 of Chapter 10 in the Modern Robotics textbook by Frank Chongwoo Park and Kevin M. This is my final project for CSPB 2270. Slides, notes, assignments, code: irom-lab.princeton.edu/intro-to-robotics. In this video we're going to discuss Implementation of eRRT algorithm in C Kinodynamic RRT applied to the autonomous inspection problem. Utilizes planar CWH equations and optimal guidance to ...