Looking for the latest information on Potential Field Method Path Planning? We've researched comprehensive data, records, and insights about Potential Field Method Path Planning.
Important Facts
Explore the primary sources for Potential Field Method Path Planning.
Recent Updates
Stay updated on Potential Field Method Path Planning's latest milestones.
Path Planning of Robotic Manipulators - Part 4 / Potential Field Method; Gradient Descent; PRM; D*
Modern Robotics, Chapter 10.6: Virtual Potential Fields
Path Planning of Robotic Manipulators - Part 3 / Potential Field Method
Potential Field Methods(Part-1): Lecture-14
Robot Motion Planning - Artificial Potential Field Method
Path planning through Potential Field method
Path Planning Using 2D Artificial Potential Fields
Path planning using Artificial Potential Field approach
Potential field method - path planning
Motion Planning using Path Guidance and a Artificial Potential Field
Dynamic Path Planning Using Electrostatic Potential Field
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: September 27, 2026
Future Outlook
For 2026, Potential Field Method Path Planning remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
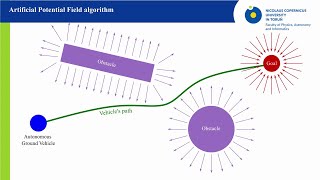
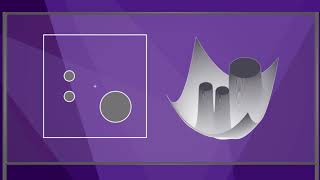
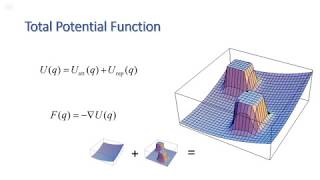
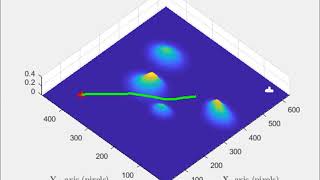
A brief presentation of the Predictive Artificial robotics It takes a significant amount of time and energy to create these free video ... The experimental and simulation verification of the proposed Advanced Artificial This is our fourth and last lecture on the topic of This is a video supplement to the book "Modern Robotics: Mechanics, This is our third lecture on the topic of Subject: Mechanical Engineering and Science Course: Robot Motion A course project in UM ROB550. A downward-looking detects objects on the table (assuming static environment), and the ... In this video, we explore how artificial Avoidance of hundreds of moving obstacles using a