Data is compiled from public records and verified media reports.
Last Updated: September 26, 2026
Future Outlook
For 2026, Multi Agent Pathfinding remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
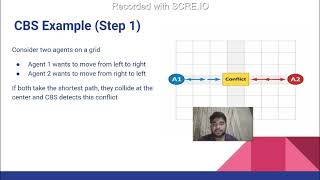
Summary
Theta* for geometric path planning. ORCA for path following with collision avoidance. Ad-hoc deadlock detection mechanism. Short presentation of the paper: Shaull Almagor and Morteza Lahijanian, "Explainable This talk aims to invite you to the forefront of MAPF research directly This is a re-recording of my invited talk at EurMAPF-25, ... J. Kottinger, S. Almagor, and M. Lahijanian, “Conflict-Based Search for Explainable This is a poster teaser talk for the paper "A Hierarchical Approach to RBE 550: Motion Planning Project Proposal Presentation Team: Dheeraj Bhogisetty, Shiva Surya Lolla and Siyuan Huang ... Two teams of 5 robots playing in RoboCup MSL league are simulated, each player has to move to a different place every 4 ... You can find more material on the tutorial website: mapf.info/index.php/Tutorial/AAMAS-22. ICAPS 2020 talk on the paper Han Zhang, Jiaoyang Li, Pavel Surynek, Sven Koenig, T. K. Satish Kumar. This video shows the fundamental features of