Looking for the latest information on Orb Slam3 Deployed On A Quadrotor? We've compiled comprehensive data, records, and insights about Orb Slam3 Deployed On A Quadrotor.
Main Features
Explore the primary sources for Orb Slam3 Deployed On A Quadrotor.
Recent Updates
Stay updated on Orb Slam3 Deployed On A Quadrotor's newest achievements.
Autonomous Exploration of a Drone (quad rotor) using The Monocular ORB SLAM
Towards Autonomous Flight of MAVs using ORB-SLAM
Install ORB SLAM3 in Ubuntu 20.04
Monocular SLAM with ORB-SLAM3 and Raspberry Pi Camera Module V2
[EE405] Generating Map using ORB SLAM3
ORB SLAM 3 demo with RealSense 435 monocular camera
Indoor drone navigation using Monocular Orb Slam 3 and ROS
ICRA 2026 Keynote Tutorial - Learning Agile Vision-based Quadrotor Flight
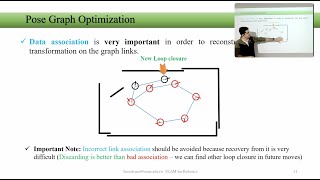
CH13 SLAM for Robotics Course - ORB-SLAM algorithm details, Pose Graph Optimization, (SIFT, ORB)
Autonomous Tello Drone ORB-SLAM System
Time-Optimal Online Replanning for Agile Quadrotor Flight (RAL 2022)
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: October 4, 2026
Summary
For 2026, Orb Slam3 Deployed On A Quadrotor remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
slam [Model] DJI SPARK [Place] Hanondg Glabal University OH [Video Info] size - 1920 x ... Repo: github.com/luigifreda/pyslam. This is a demonstration of ORB_SLAM3 performing visual SLAM to produce a 3D trajectory from The aim of this Project is the Autonomous Exploration of a Nils Lowen , José Martínez-Carranza, Francisco Marquez, Esteban O. Garcia, and Walterio Mayol-Cuevas. Accepted to be ... The command: github.com/Mauhing/ORB_SLAM3/blob/master/README.md Reference: ... waypoint based navigation for monocular indoor drones. Setup instruction and ROS packages references at: ... Recent advances in learning-based control have enabled Simultaneous Localization and Mapping (SLAM) Course In this Chapter: - Mapping (No Uncertainty) - Mapping (with uncertainty) ... In this paper, we tackle the problem of flying a