About of Deep Reinforcement Learning For Autonomous Robot Navigation
Looking for the latest information on Deep Reinforcement Learning For Autonomous Robot Navigation? We've compiled comprehensive data, records, and insights about Deep Reinforcement Learning For Autonomous Robot Navigation.
Main Features
Explore the main sources for Deep Reinforcement Learning For Autonomous Robot Navigation.
Recent Updates
Stay updated on Deep Reinforcement Learning For Autonomous Robot Navigation's newest achievements.
Autonomous Multi-View Navigation via Deep Reinforcement Learning
Deep Reinforcement Learning for Autonomous Navigation in Dynamic Environments - CASE 2020
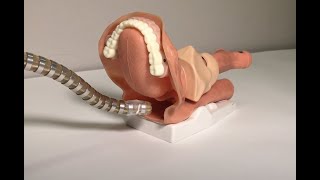
Deep Q Reinforcement Learning for Autonomous Navigation of Surgical Snake Robot in Confined Spaces
Autonomous Navigation of Unmanned Vehicle Through Deep Reinforcement Learning - ArXiv:24
Decentralized Multi-agent Collision Avoidance with Deep Reinforcement Learning
Virtual-to-real Deep Reinforcement Learning: Mobile Robots Mapless Navigation
Deep Reinforcement learning for real autonomous mobile robot navigation
Autonomous Navigation of Unmanned Vehicle Through Deep Reinforcement Learning - ArXiv:24
Deep Reinforcement Learning for Autonomous Navigation in Robotic Wheelchairs
Deep Reinforcement Learning Methods for Autonomous Driving Safety and Interactivity
Robot Navigation of Environments with Unknown Rough Terrain Using Deep Reinforcement Learning
Full Guide
Data is compiled from public records and verified media reports.
Last Updated: October 5, 2026
Future Outlook
For 2026, Deep Reinforcement Learning For Autonomous Robot Navigation remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Mickyas Tamiru Asfaw, David Bertoin, Valentin Guillet develop a Bruno Fournier and Sébastien Biner develop and evaluate This is the supplementary video. 2020 IEEE 16th International Conference on Automation Science and Engineering (CASE), August 2020 Hong Kong. This video introduces the development of a Original paper: arxiv.org/abs/2407.18962 Title: (IROS 2017) arxiv: arxiv.org/abs/1703.00420 A continuous control policy is trained via the Soft Actor Critic (SAC) algorithm for autonomously navigating a differential drive Ph.D. thesis defense of Xiaobai Ma. Slides available at web.stanford.edu/group/sisl/public/defense_ma.pdf. K. Zhang, F. Niroui, M. Ficocelli and G. Nejat, “
Deep Reinforcement Learning For Autonomous Robot Navigation.pdf
What is the most accurate information about Deep Reinforcement Learning For Autonomous Robot Navigation?
Our platform aggregates the most comprehensive and up-to-date insights, ensuring you get relevant details about Deep Reinforcement Learning For Autonomous Robot Navigation.
Why is Deep Reinforcement Learning For Autonomous Robot Navigation trending right now?
Interest in Deep Reinforcement Learning For Autonomous Robot Navigation has surged recently as more people seek reliable resources, related media, and detailed analysis.
Where can I find related media and updates for Deep Reinforcement Learning For Autonomous Robot Navigation?
You can explore extensive galleries, video summaries, and related content directly on this page.
How often is the content about Deep Reinforcement Learning For Autonomous Robot Navigation updated?
We regularly update our database with the latest information, media, and analysis related to Deep Reinforcement Learning For Autonomous Robot Navigation.