Looking for the latest information on Wheel Odometry Experiments? We've researched comprehensive data, records, and insights about Wheel Odometry Experiments.
Important Facts
Explore the main sources for Wheel Odometry Experiments.
Latest News
Stay updated on Wheel Odometry Experiments's newest achievements.
Obstacle Detection for Self-Driving Cars Using Only Monocular Cameras and Wheel Odometry
Quantum Leap 4 Wheel Odometry System Reveal
ATCart's wheel hall sensor for wheel odometry with robot_pose_ekf package
OmniCar with video stream and wheel odometry
P3-AT driving, pure wheel odometry
Odometry and compass odometry pose estimate comparison
SLAMcore Wheel Odometry Integration Demo
Robot Drives in a Circle Using Odometry
OmniCar with ORB-SLAM2 and wheel odometry
Wheel Odometry based Localisation at IIT Kharagpur
LiDAR-IMU-Wheel Odometry with Online Calibration of a Kinematic Model for Skid-Steering Robots
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: September 30, 2026
Conclusion
For 2026, Wheel Odometry Experiments remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
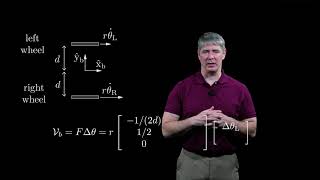
This is a video supplement to the book "Modern Robotics: Mechanics, Planning, and Control," by Kevin Lynch and Frank Park, ... Using a borescope camera to test whether or not the suspension in the Join the community & access CAD files, Code snippets, & more robotics resources ⤵️ shop.broganpratt.com/ Get 5% ... The documents attempts to provide an overview on how autonomously navigating robots and vehicles can be achieved by using a ... Supplementary video to the paper: C. Häne, T. Sattler, M. Pollefeys, Obstacle Detection for Self-Driving Cars Using Only ... Stay tuned for the full MTI Robot Reveal!!! Short demonstration of OmniCar project GitHub Pages: divelix.github.io/OmniCar/ P3-AT driving autonomously using pure This video illustrates two dead reckoning pose estimations. The blue robot is a differential drive robot (i.e. the ground truth). How can sensor fusion improve SLAMcore's localization and mapping accuracy and robustness? In this video, we compare ... Robot uses BASIC Stamp, simple 2-speed motor control relays and optical Project Page: rishabh-singh.in/ Open-source (Please copy and paste the following link): github.com/TakuOkawara/full_linear_wheel_odometry_factor This video ...