Looking for the latest information on W4733 Lab2 Bug 2 Algorithm World 0? We've researched comprehensive data, records, and insights about W4733 Lab2 Bug 2 Algorithm World 0.
Key Details
Explore the main sources for W4733 Lab2 Bug 2 Algorithm World 0.
Latest News
Stay updated on W4733 Lab2 Bug 2 Algorithm World 0's newest achievements.
The Bug 2 Algorithm
“Bug 2” algorithm | Gaezbo + ROS | Two wheeled mobile robot
Local Path Planning with obstacle avoidance using Bug 2 Algorithm
Bug 2 Algorithm
Bug Algorithm Python - Bug 0, Bug 1 & Bug 2
Lab 2 Task 4: Webots Bug Zero Algorithm
Bug 2 algorithm in V-REP simulator
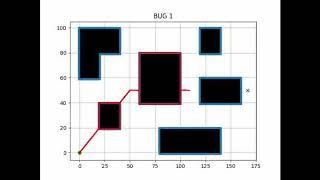
Demonstration of Bug 1 and 2 algorithms
Bug2 - Path Planning Algorithm Explanation
Bug 2 Algorithm, Course 1
“Bug 2” algorithm | Gazebo + ROS | Two wheeled mobile robot
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: September 27, 2026
Future Outlook
For 2026, W4733 Lab2 Bug 2 Algorithm World 0 remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Lecture 1.4. Wherein we introduce and explore the operation of the Github github.com/KirillGordievich/bug_algorithms_gazebo. This task was by far the most challenging but rewarding. This task demonstrates the ME133b Final Project Evan Yu, Amarbold Batzorig. Call the line from the starting point to the goal the m-line 1) head toward goal on the m-line