Robotic assembly trajectory planning of beam structures in PyBullet
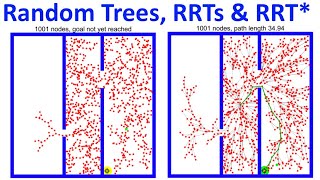
Python implementation of the RRT algorithm
Sampling Based Path Planning: RRT*
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: September 30, 2026
Summary
For 2026, Rrt Algorithm Pybullet remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
A first go at making a motion planner with the rapidly exploring random tree ( EECS498 Introduction to Algorithmic Robotics Final Project (2021 Fall) 0:01 Draw the search tree (blue) 1:50 Draw the planned ... See the other videos in this series: youtube.com/playlist?list=PLn8PRpmsu08rLRGrnF-S6TyGrmcA2X7kg This video ... Sliding mode nonlinear controller was used to stabilize the robot at desired configurations. Github: ... Following on from my last implementation with Lecture 24 of Intro to Robotics @ University of Houston. using ... Here we see the simulation of the navigation of a differential drive robot using art This video presents a robotic trajectory planning For details see: github.com/nimRobotics/