Looking for the latest information on Ros2 Occupancy Grid Node For Nav2? We've gathered comprehensive data, records, and insights about Ros2 Occupancy Grid Node For Nav2.
Key Details
Explore the primary sources for Ros2 Occupancy Grid Node For Nav2.
History
Stay updated on Ros2 Occupancy Grid Node For Nav2's latest milestones.
Understanding Autonomous Navigation in ROS2: Mapping, Planning, and Execution
A Path Planning + Potential Field Controller | ROS2 Navigation WITHOUT Nav2**
ROS2 Nav2 Integration : Understanding YAML Parameters for Planners, Costmaps, and Velocities
[ROS2 Q&A] 237 - How to spawn robot from sam_bot nav2 tutorial
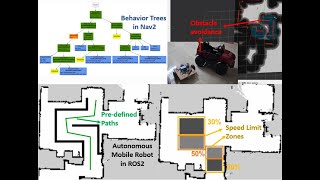
Navigation2 in ROS2 | Autonomous Mobile Robot | Nav2 | Behavior Trees | Odrive| Diff drive Robot
ROS2 Nav2 Route Server | Custom Map & Node-Based Navigation
ROS2 Nav2: Shelf Inspection Demonstration with Keep-Out Zones
[ROS2 Q&A] 232 - How to follow waypoints using nav2
occupancy grid map- ros
Nav2 Mapping with SLAM Toolbox | ROS2 Developers Open Class #137
ROS2 Nav2 tutorial | Create a map with slam_toolbox, Nav2 and Ignition Gazebo
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: September 30, 2026
Final Thoughts
For 2026, Ros2 Occupancy Grid Node For Nav2 remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
A structured learning path for becoming a robotics developer. : bit.ly/4v1OplB Ubuntu Version : 22.04 Companion blog post coming soon 💻️ GitHub code at the end of this tutorial ... This is my robotics navigation project for the KELO Robile platform using ** This video answers the question posted at ROS answers: ... This video is about the navigation2 in In this video, I demonstrate autonomous robot navigation using the Code can be found: github.com/SteveMacenski/nav2_rosdevday_2021 as part of the demonstrations for ROS Developers ... A brief description of the video... You'll learn: - How to launch a functional Mapping is an essential part of Navigation. In order to make a robot navigate autonomously, it needs to have a Timestamps ⏱️ 0:00 Start 0:50 I know what you are thinking 1:34