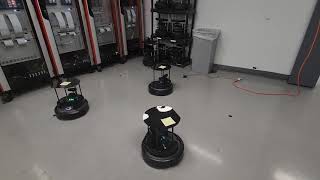
Looking for the latest information on Robot Formation Based On Turtlebot? We've gathered comprehensive data, records, and insights about Robot Formation Based On Turtlebot.
Core Information
Explore the key sources for Robot Formation Based On Turtlebot.
Developments
Stay updated on Robot Formation Based On Turtlebot's newest achievements.
Turtlebot attitude consensus
Bearing based formation using 4 Turtlebots
[HeRoLab] HeRoSwarm - Multi-Robot Formation Control Demo
Three Turtlebots forming an equitriangular formation while following a sinusoid trajectory
Multi-robot cycling with Turtlebot4
Cooperative Object Transportation With Obstacle Avoidance for Multi-Robot System - ROS TurtleBot3
Three Turtlebots forming a linear formation and following a circular trajectory
Turtlebot 2 Experiments
Testing Multiple Turtlebot
Bearing based formation using 4 Turtlebots - one diagonal connection
Autonomous Navigation and Formation Control Algorithm Application on Turtlebots
Full Guide
Data is compiled from public records and verified media reports.
Last Updated: September 27, 2026
Final Thoughts
For 2026, Robot Formation Based On Turtlebot remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Using the developed Type-2 fuzzy controller, two This video shows 3 Turtlebot2 robots given initial angles and afterwards applying MAS consensus protocol in order to achieve ... This experiment uses bearing control The HeRoSwarm project from the Heterogeneous Turtlebot4s maintain a fixed relative position during cycling, deployed by Saimai Lau. Implementation of a leader follower This video depicts fundamental experimentations done using Turtle is derived from the Turtle