Looking for the latest information on Orb Slam? We've gathered comprehensive data, records, and insights about Orb Slam.
Core Information
Explore the primary sources for Orb Slam.
Developments
Stay updated on Orb Slam's latest milestones.
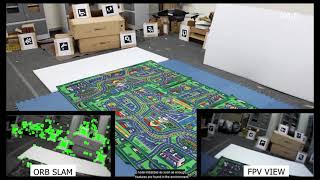
ORB SLAM YOLO
ORB-SLAM 2 - mapping a City, Simultaneous Localization And Mapping Test
ORBSLAM 2 Stereo
ORB-SLAM3 Visual SLAM Pipeline Explained — 3D Animation (Manim)
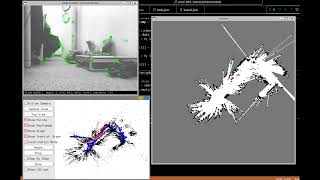
Testing Python SLAM with ORB Features (accelerated)
Loop Closure Example in ORB SLAM
Visual SLAM Webinar: ORB-SLAM2 Paper & Code Review (English)
ORB SLAM-3 Simulation test
ORB-SLAM: Mapping KAIST campus with Monocular Camera
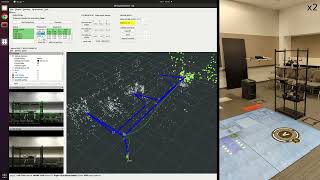
Indoor drone navigation using Monocular Orb Slam 3 and ROS
ORB-SLAM vs motion capture system Augmented Reality comparison
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: October 2, 2026
Summary
For 2026, Orb Slam remains one of the most talked-about information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
This is a demonstration of ORB_SLAM3 performing visual A Parrot AR Drone 2.0 is used with a maximum flight time of 12 min in indoor conditions as the aerial agent with a onboard ... Get FREE Robotics & AI Resources (Guide, Textbooks, Courses, Resume Template, Code & Discounts) – Sign up via the pop-up ... Repo: github.com/luigifreda/pyslam. Done as a part of the ESE 650 project. For more information, please visit our website. vdclab.kaist.ac.kr/bbs/board.php?bo_table=sub2_2&sca=Localization. waypoint based navigation for monocular indoor drones. Setup instruction and ROS packages references at: ... On the left, the localization of the camera is computed using