Introduction of Icra 2020 Experiments A Distributed Source Term Estimation Algorithm For Multi Robot Systems
Looking for the latest information on Icra 2020 Experiments A Distributed Source Term Estimation Algorithm For Multi Robot Systems? We've researched comprehensive data, records, and insights about Icra 2020 Experiments A Distributed Source Term Estimation Algorithm For Multi Robot Systems.
Core Information
Explore the main sources for Icra 2020 Experiments A Distributed Source Term Estimation Algorithm For Multi Robot Systems.
Developments
Stay updated on Icra 2020 Experiments A Distributed Source Term Estimation Algorithm For Multi Robot Systems's newest achievements.
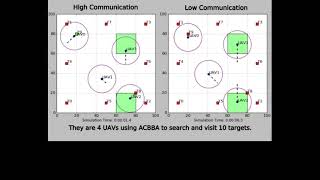
ICRA 2020: Experimental Comparison of Decentralized Task Allocation Algs. Under Imperfect Comms.
An Algorithm for Odor Source Localization based on Source Term Estimation (ICRA 2019)
Modelling Resource Contention in Multi-Robot Task Allocation Problems with Uncertain Timing
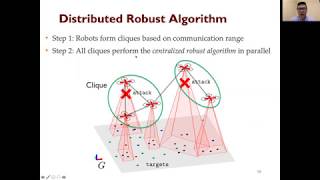
Distributed Simultaneous Action and Target Assignment for Multi-Robot Multi-Target Tracking
ICRA 2020 WS Legged Robots: Poster 1 - [Justin K. Yim et al.]
Multi-Agent Task Allocation using Cross-Entropy Temporal Logic Optimization (ICRA 2020)
An Efficient NSGA-II-based Algorithm for Multi-Robot Coverage Path Planning [ICRA 2025]
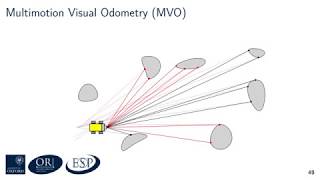
Towards Metric Multimotion Estimation - ICRA 2020 Workshop @ORI
Information Based Mobile Sensor Planning for Source Term Estimation of a Non-Continuous Atmospheric
【IEEE TRO】From Local Odometry to Global Awareness: Two-Stage Distributed Odometry for MRS
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: October 3, 2026
Final Thoughts
For 2026, Icra 2020 Experiments A Distributed Source Term Estimation Algorithm For Multi Robot Systems remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
The paper is available at infoscience.epfl.ch/record/279927 Abstract: Finding sources of airborne chemicals with mobile ... Title: Precise Leaping and Balanced Landing Authors: Justin K. Yim, B. Roodra P. Singh, Eric K. Wang, Roy Featherstone, and ... Optimal Assignment of tasks to a team of This is the presentation for our work at A presentation about our work on multimotion From Local Odometry to Global Awareness: A Two-Stage Filter-Based
Icra 2020 Experiments A Distributed Source Term Estimation Algorithm For Multi Robot Systems.pdf
What is the most accurate information about Icra 2020 Experiments A Distributed Source Term Estimation Algorithm For Multi Robot Systems?
Our platform aggregates the most comprehensive and up-to-date insights, ensuring you get relevant details about Icra 2020 Experiments A Distributed Source Term Estimation Algorithm For Multi Robot Systems.
Why is Icra 2020 Experiments A Distributed Source Term Estimation Algorithm For Multi Robot Systems trending right now?
Interest in Icra 2020 Experiments A Distributed Source Term Estimation Algorithm For Multi Robot Systems has surged recently as more people seek reliable resources, related media, and detailed analysis.
Where can I find related media and updates for Icra 2020 Experiments A Distributed Source Term Estimation Algorithm For Multi Robot Systems?
You can explore extensive galleries, video summaries, and related content directly on this page.
How often is the content about Icra 2020 Experiments A Distributed Source Term Estimation Algorithm For Multi Robot Systems updated?
We regularly update our database with the latest information, media, and analysis related to Icra 2020 Experiments A Distributed Source Term Estimation Algorithm For Multi Robot Systems.