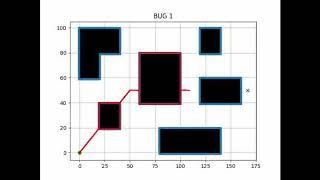
[ROS Projects] Bug 2 - Exploring ROS with a 2 wheeled robot #Part 12
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: September 26, 2026
Future Outlook
For 2026, Bug2 Algorithm In Ros remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Book : Choset, H., Lynch, K. M., Hutchinson, S., Kantor, G., Burgard, W., Kavraki, L., & Thrun, S. (2005). Principles of Robot Motion: ... Call the line from the starting point to the goal the m-line 1) head toward goal on the m-line 2) if an obstacle is in the way, it ... This video shows a simulated robot I developed in Gazebo and ROS2 that uses the Github github.com/KirillGordievich/bug_algorithms_gazebo. This scene is part of the project for the course of Autonomous Mobile Robots of the ICMC - USP Robot: Pioneer P3-DX Sensors: ...